> For the complete documentation index, see [llms.txt](https://wiki.zephyr-sim.com/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://wiki.zephyr-sim.com/getting-started/scenarios/obstacle-course.md).

# Obstacle Course

## Introduction

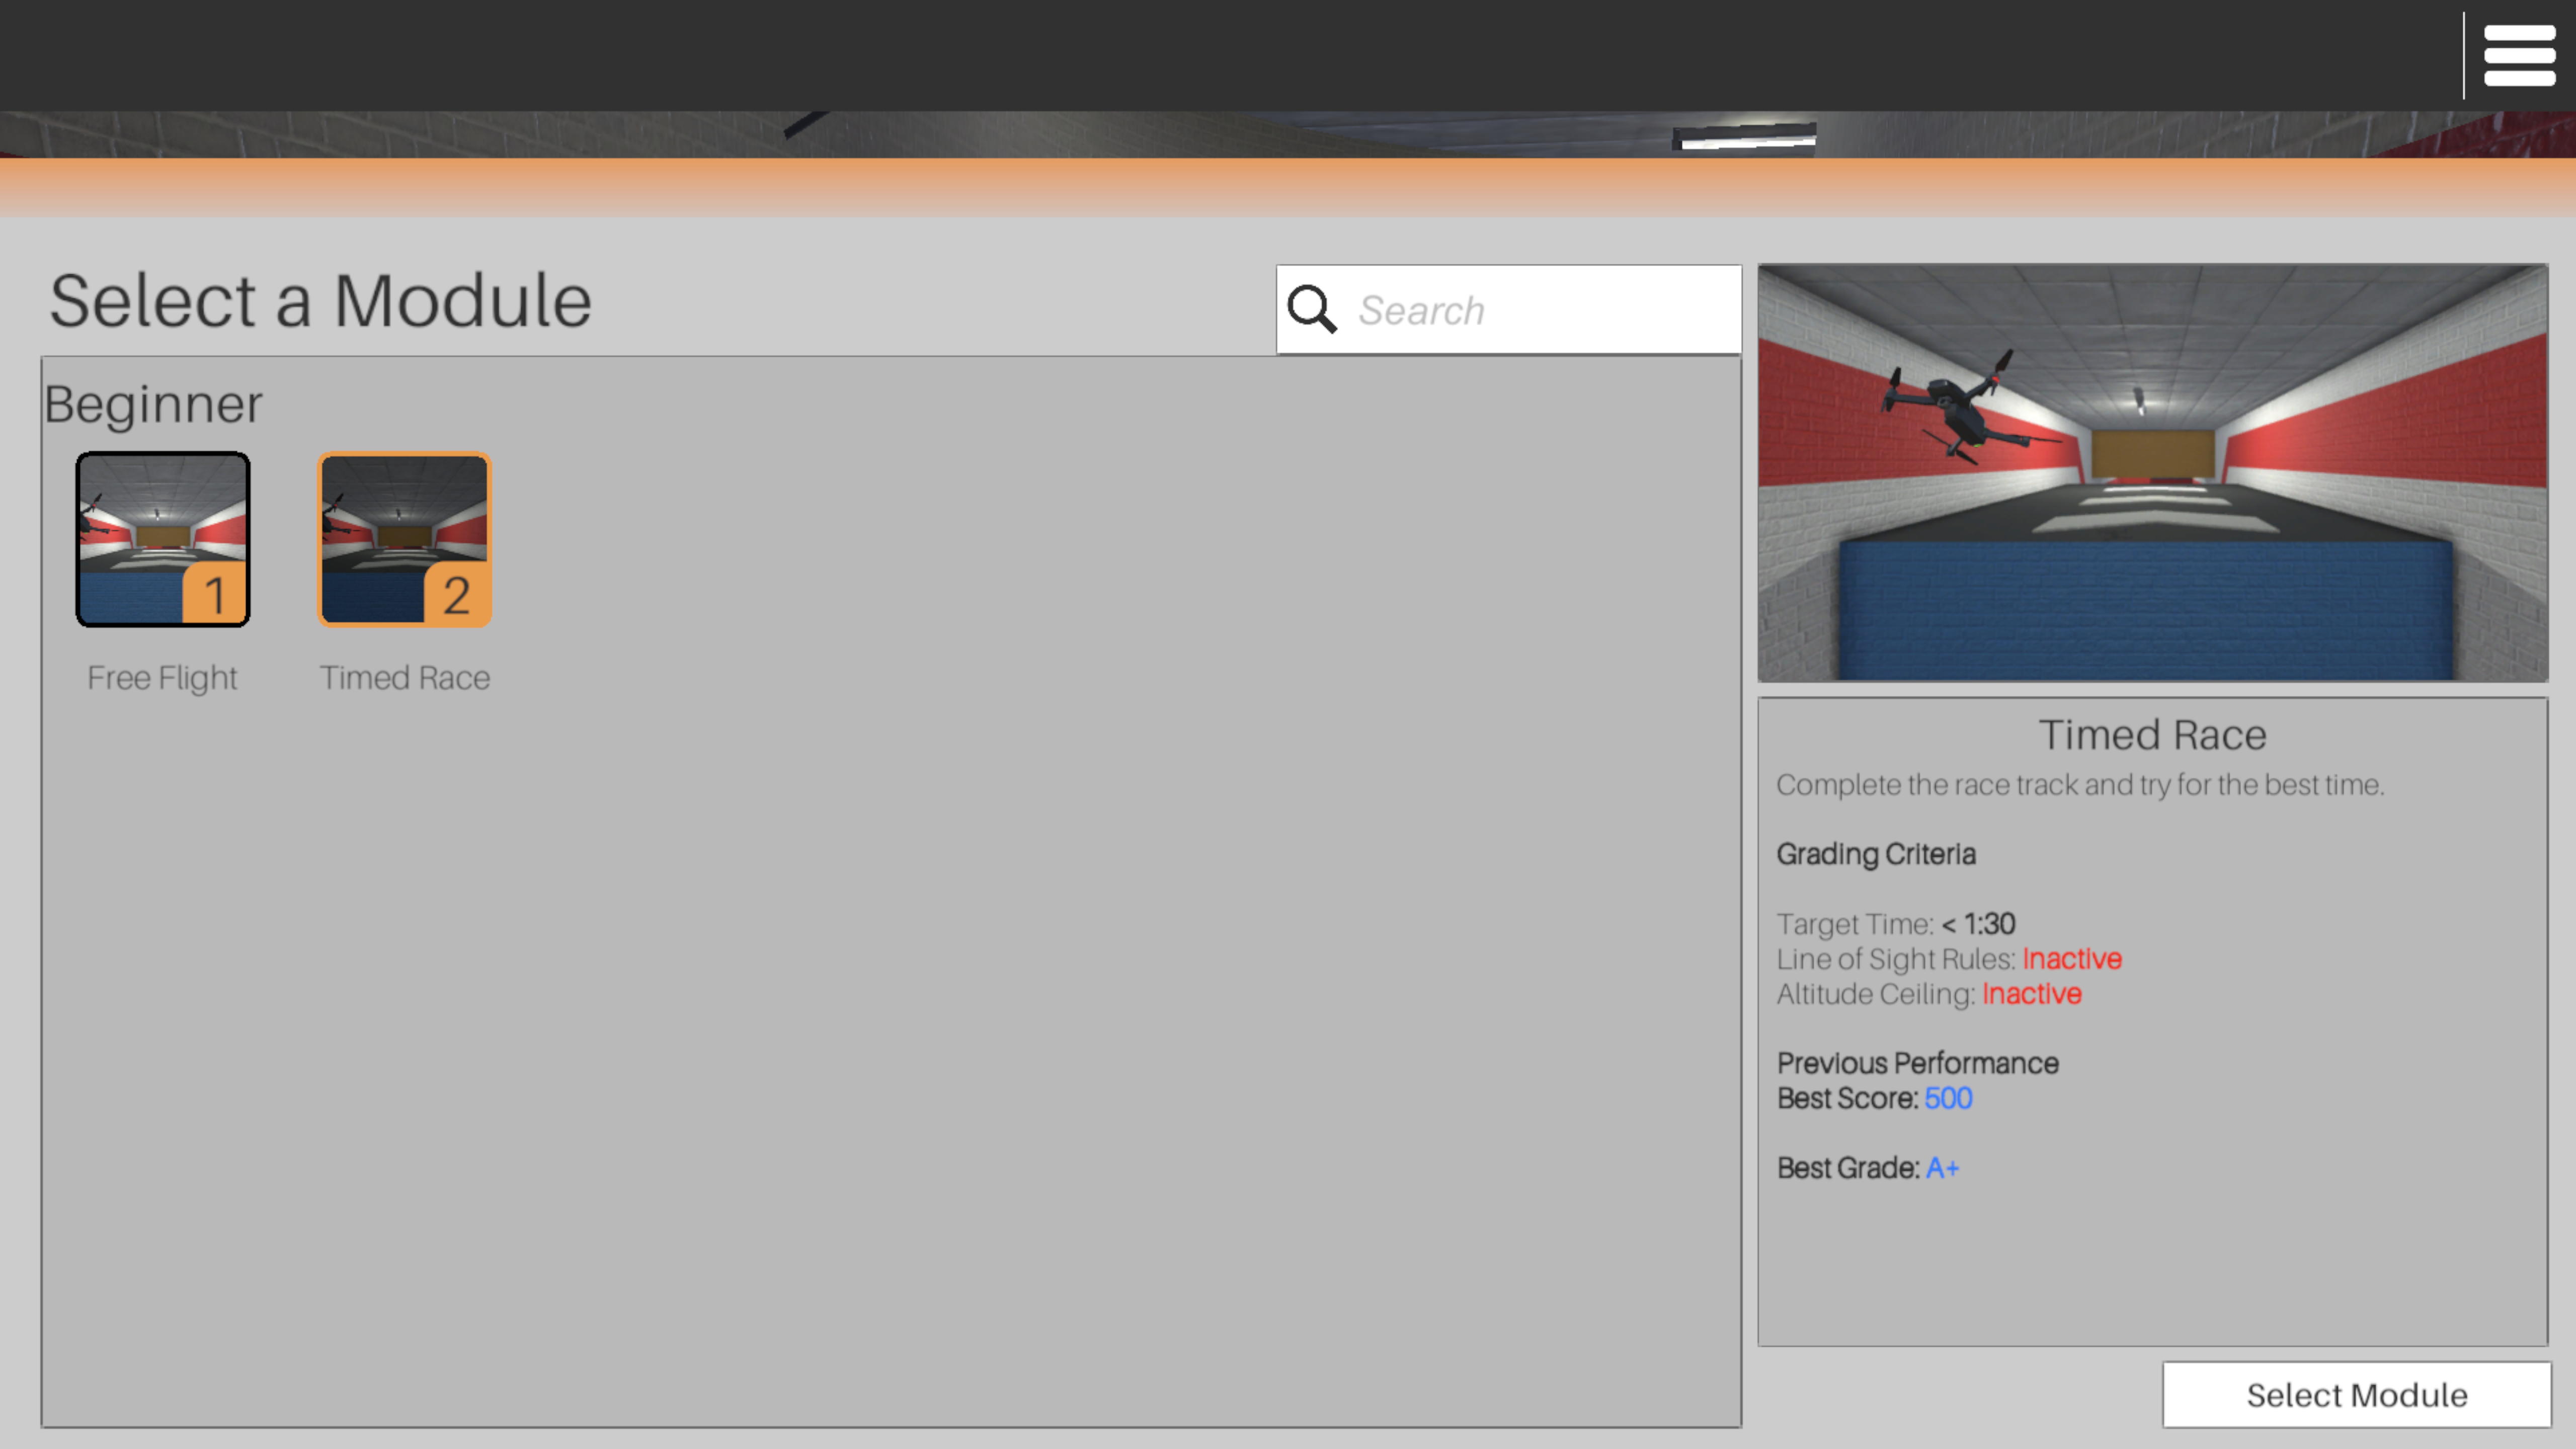
The Obstacle Course scenario is a time trial where operators pilot their drone through a tense, tightly-packed course.

The Obstacle Course scenario consists of two modules:

1. Free Flight
2. Timed Race

<figure><img src="https://1836517361-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2Fb4gMJ8PjT5QccaZNi3oB%2Fuploads%2FPEYIdtGtUIkfw1WfVhzt%2Fimage.png?alt=media&amp;token=b8bce1f4-348e-431b-ad69-9cbf2d7c2787" alt=""><figcaption></figcaption></figure>

## Drone Roster

Every module in this scenario has the following drone roster:

<details>

<summary>Drone Roster</summary>

* 3DR Solo
* AG-6A
* Alta X
* ANAFI USA
* Arrowhead
* Avata 2
* Bebop 2
* EVO II
* EVO Max 4T
* HD Racer
* Inspire 1
* Inspire 2
* Lemur 2
* Loki Mkii
* Matrice 200
* Matrice 30
* Mavic Pro
* Phantom 3
* Phantom 4
* Skydio 2
* Syma X5C
* Titan
* Typhoon
* X Star
* X10
* X2D

</details>

## Module Breakdowns

### Timed Race

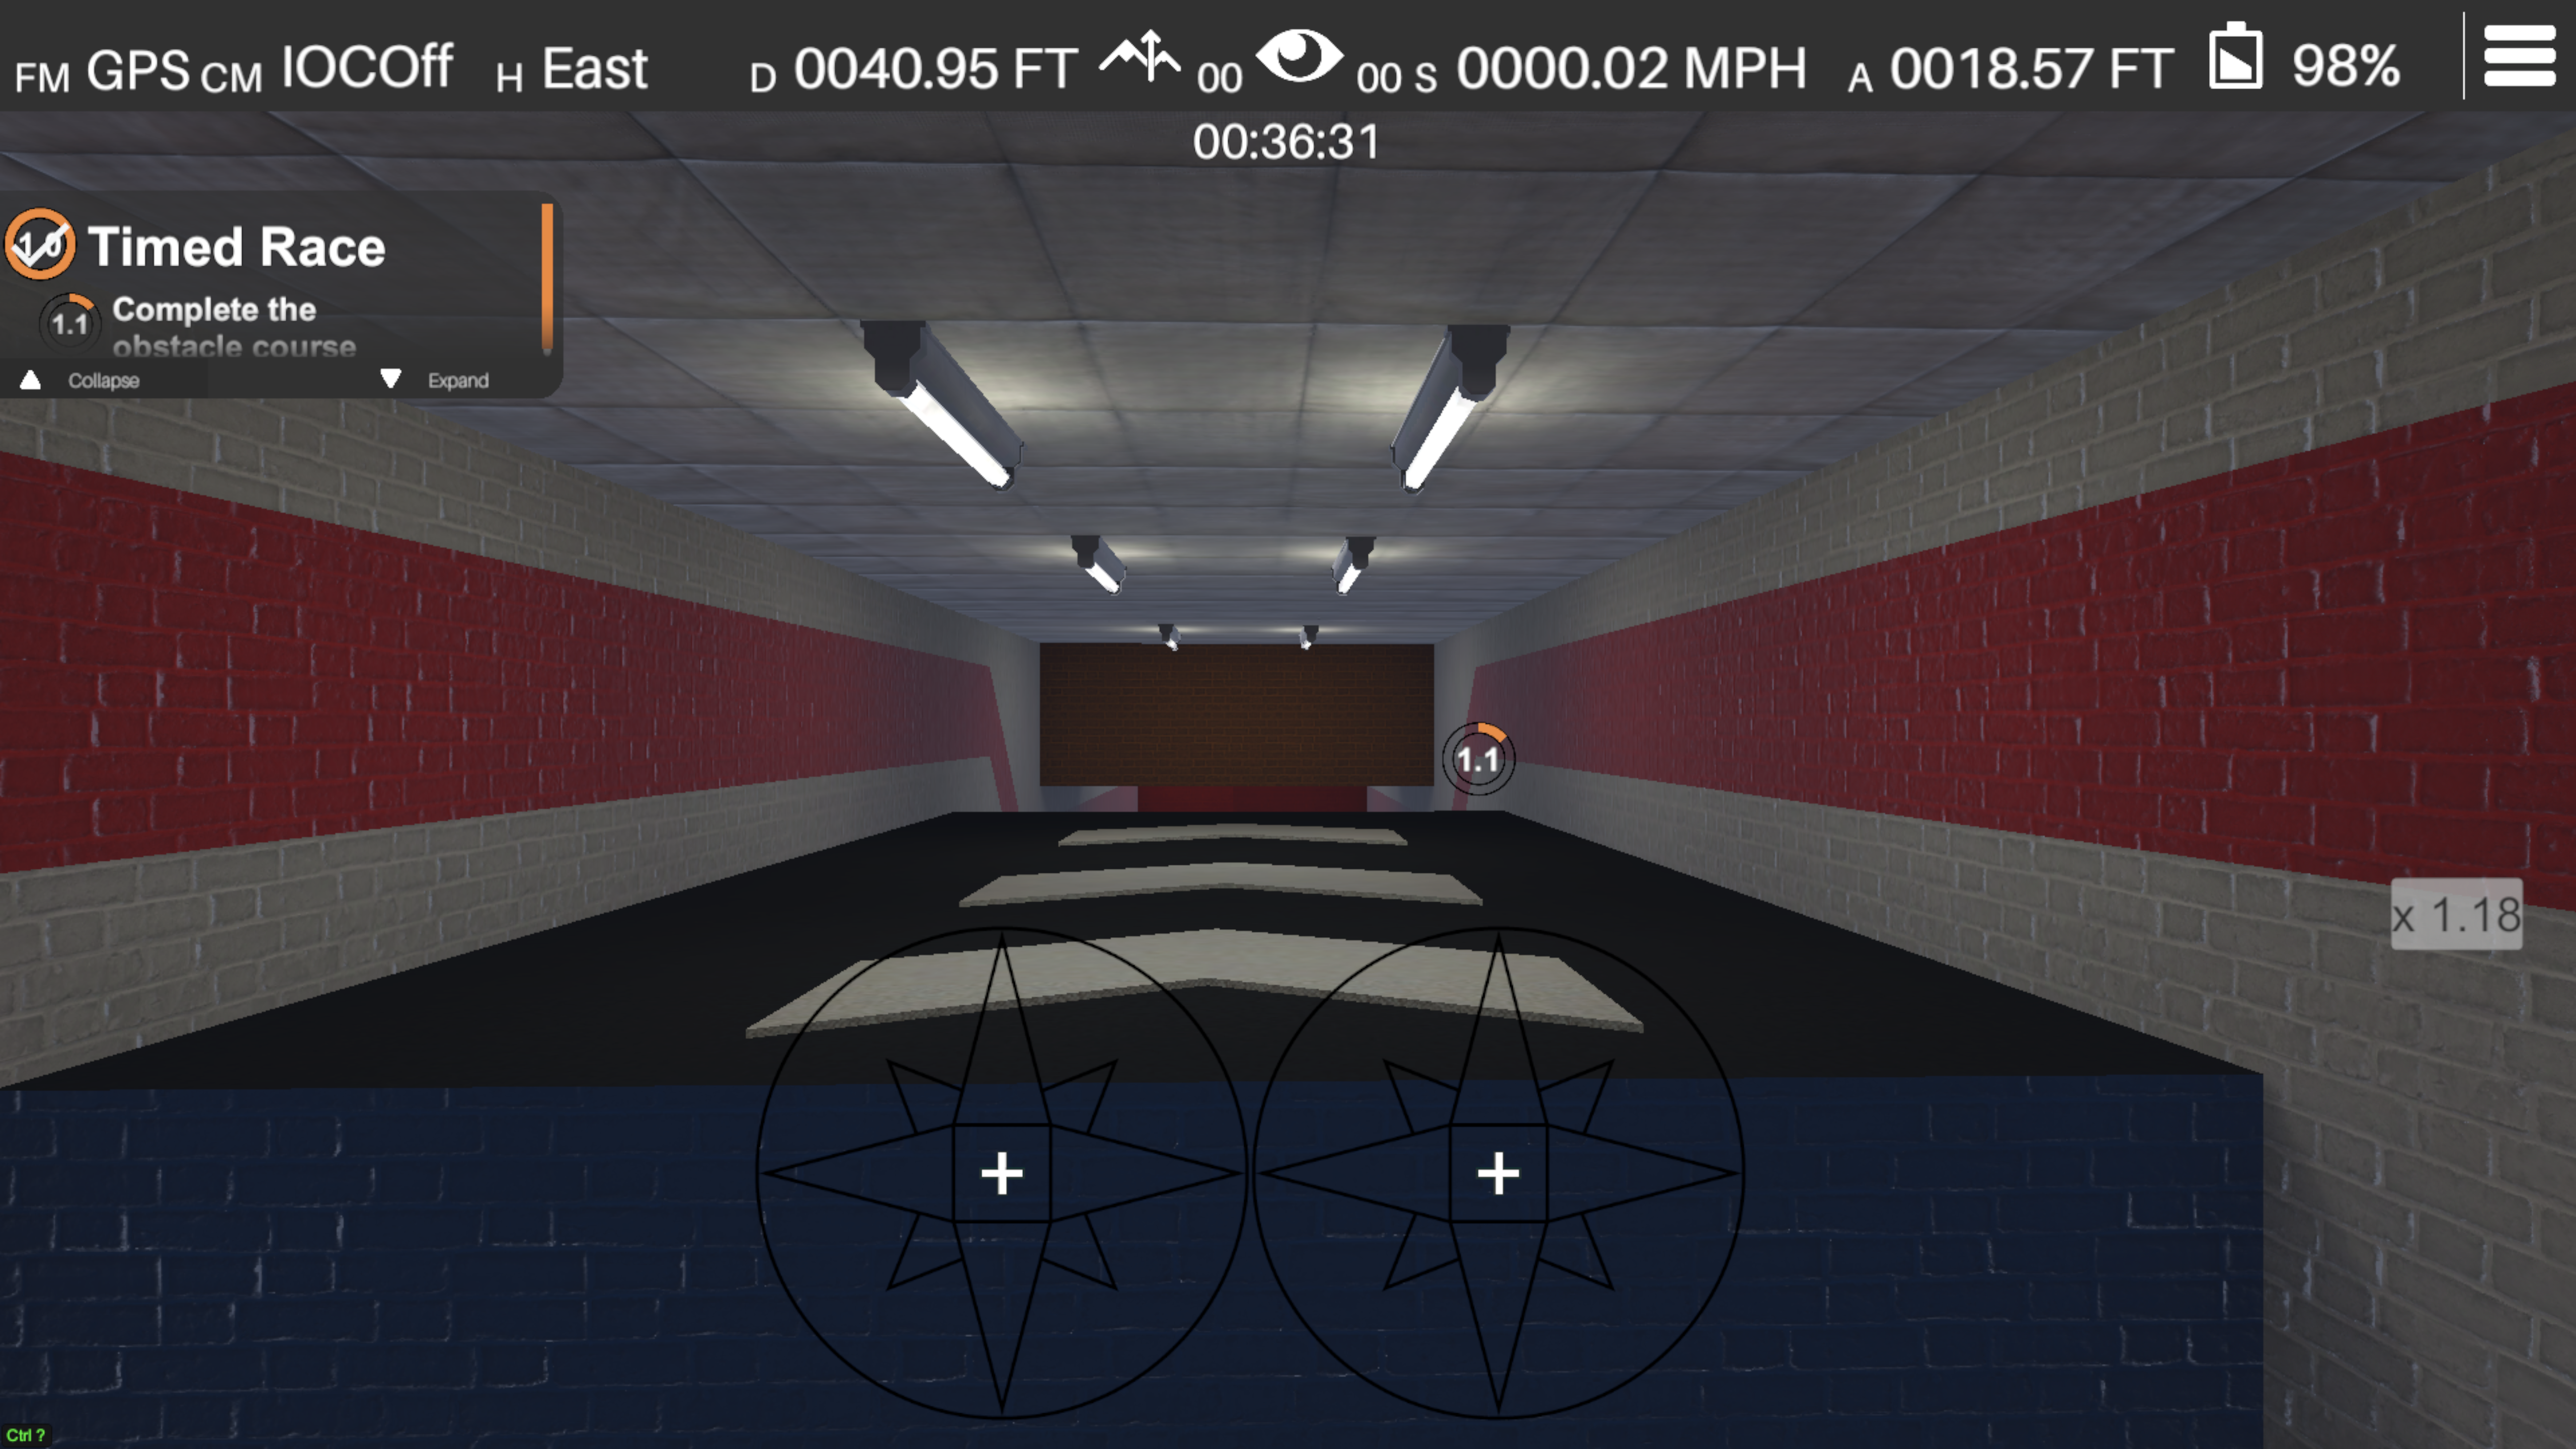
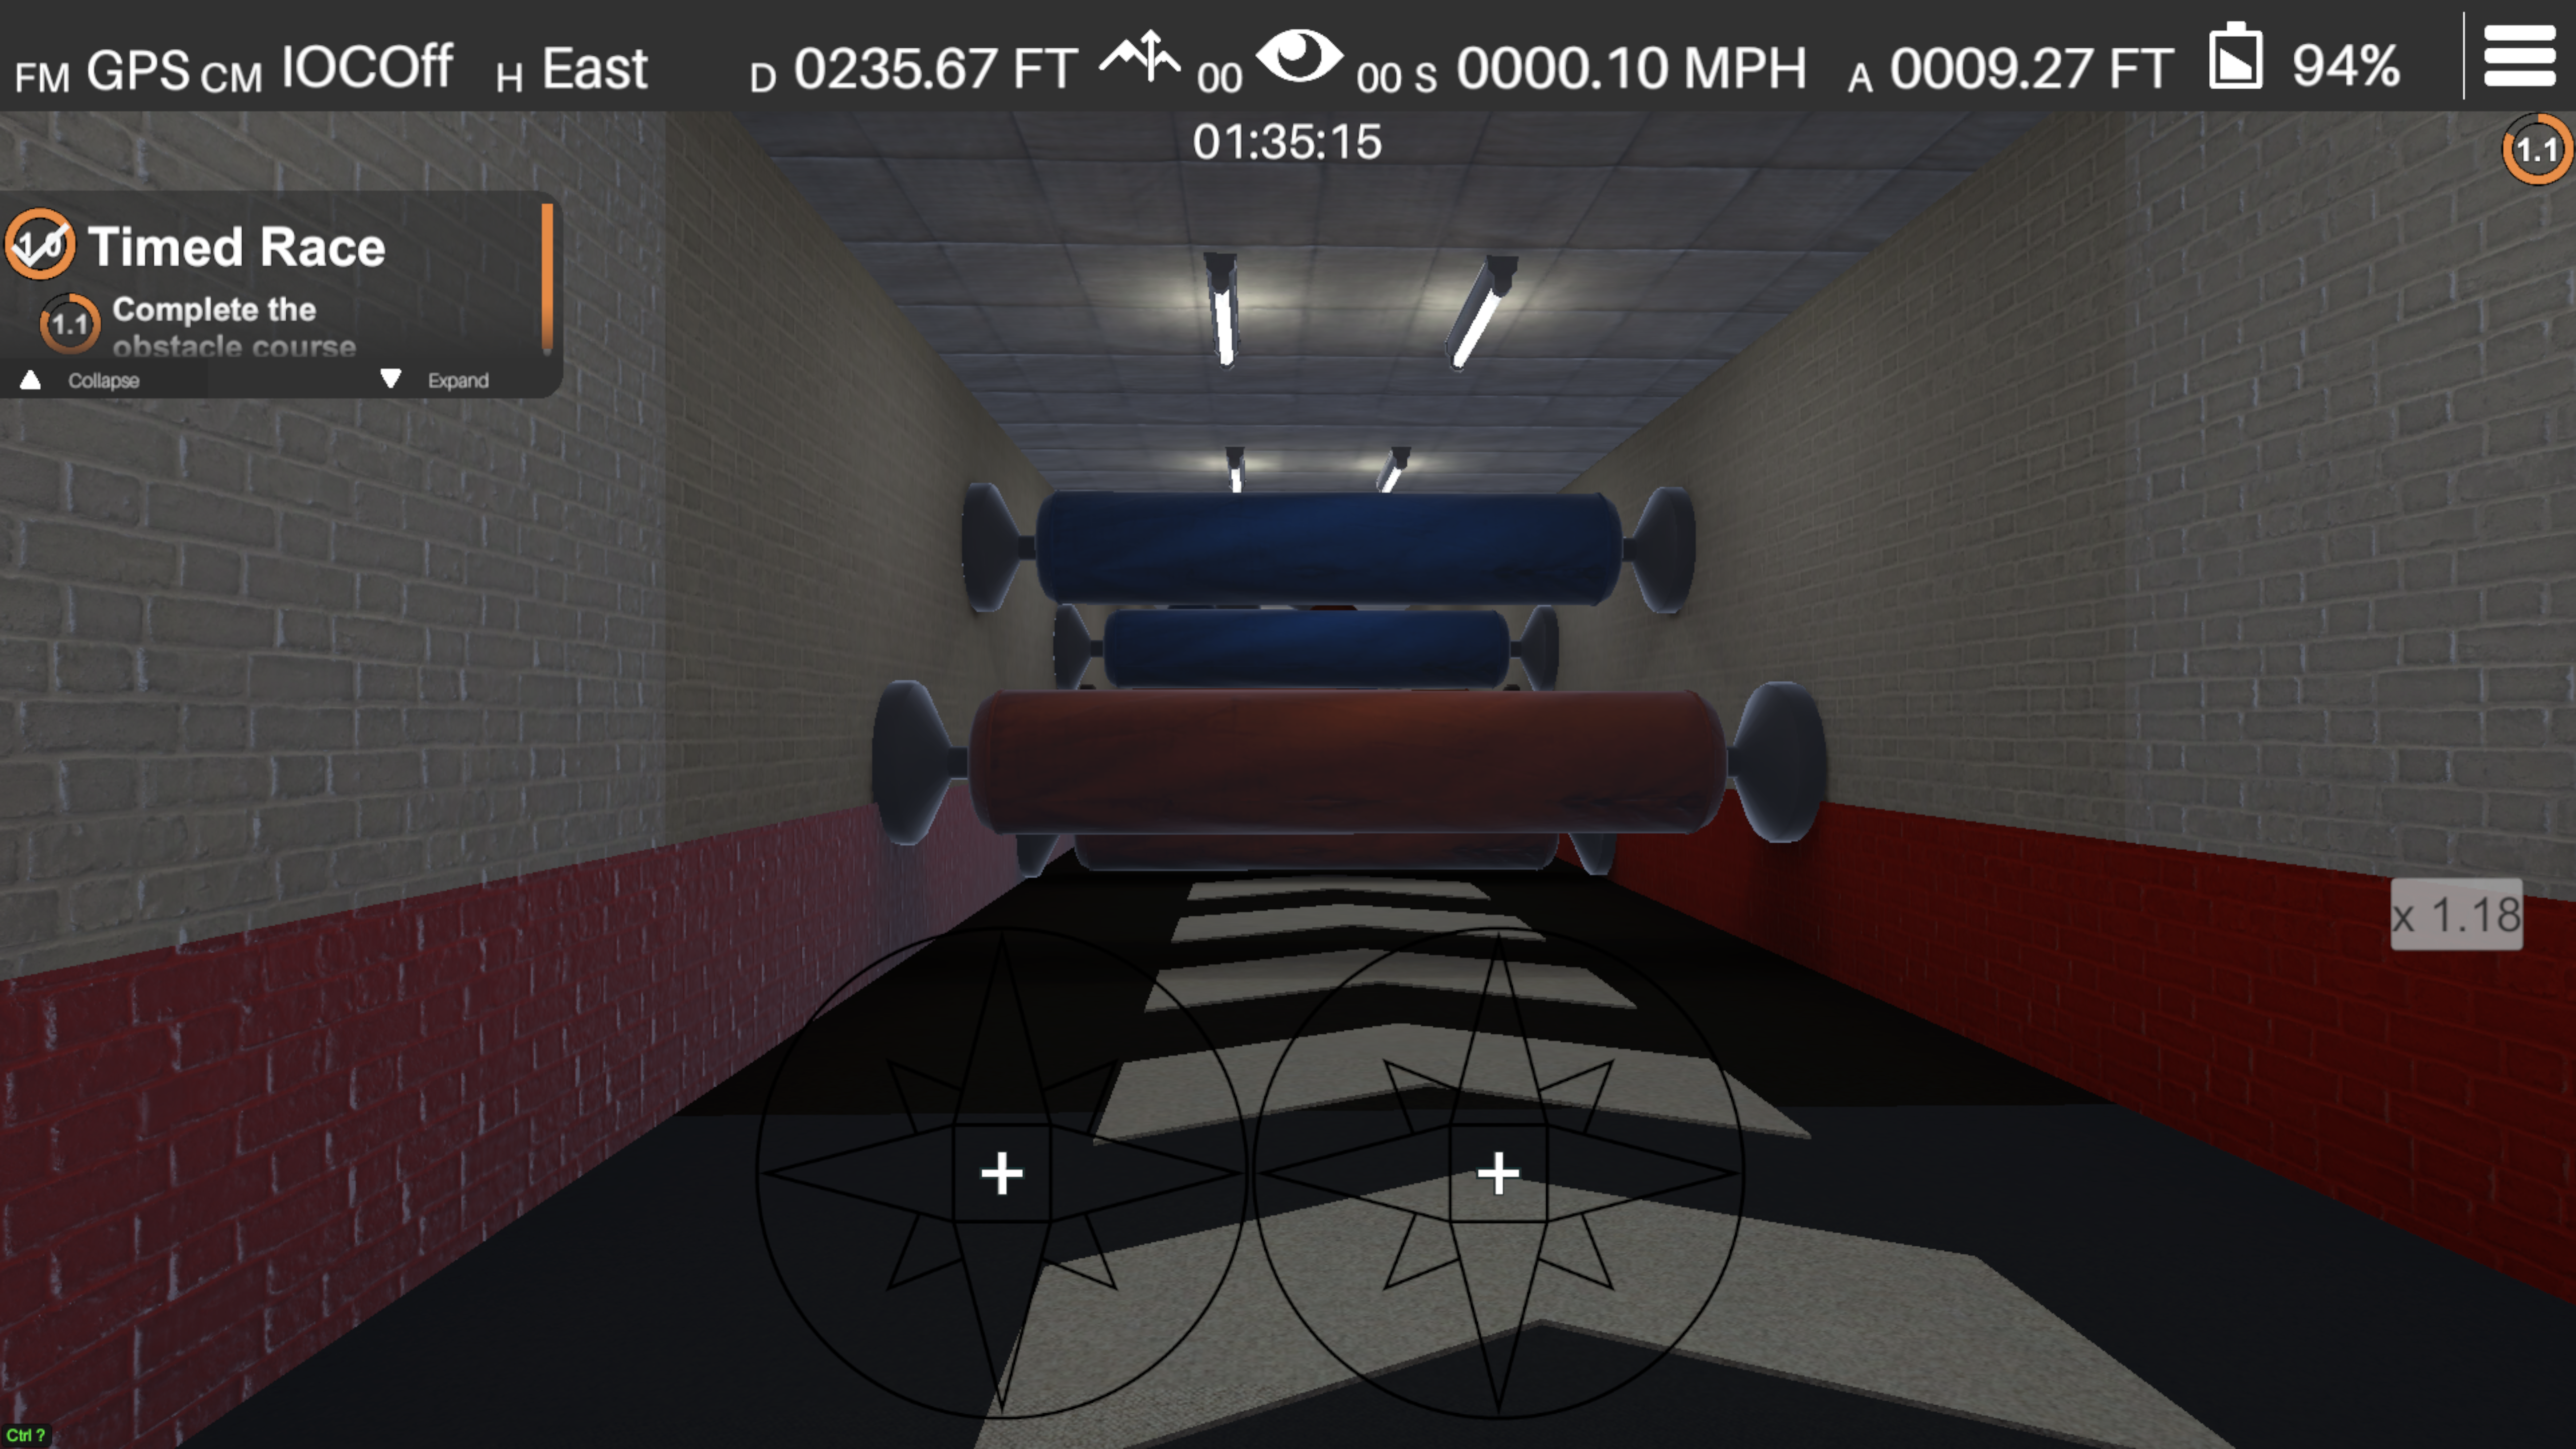
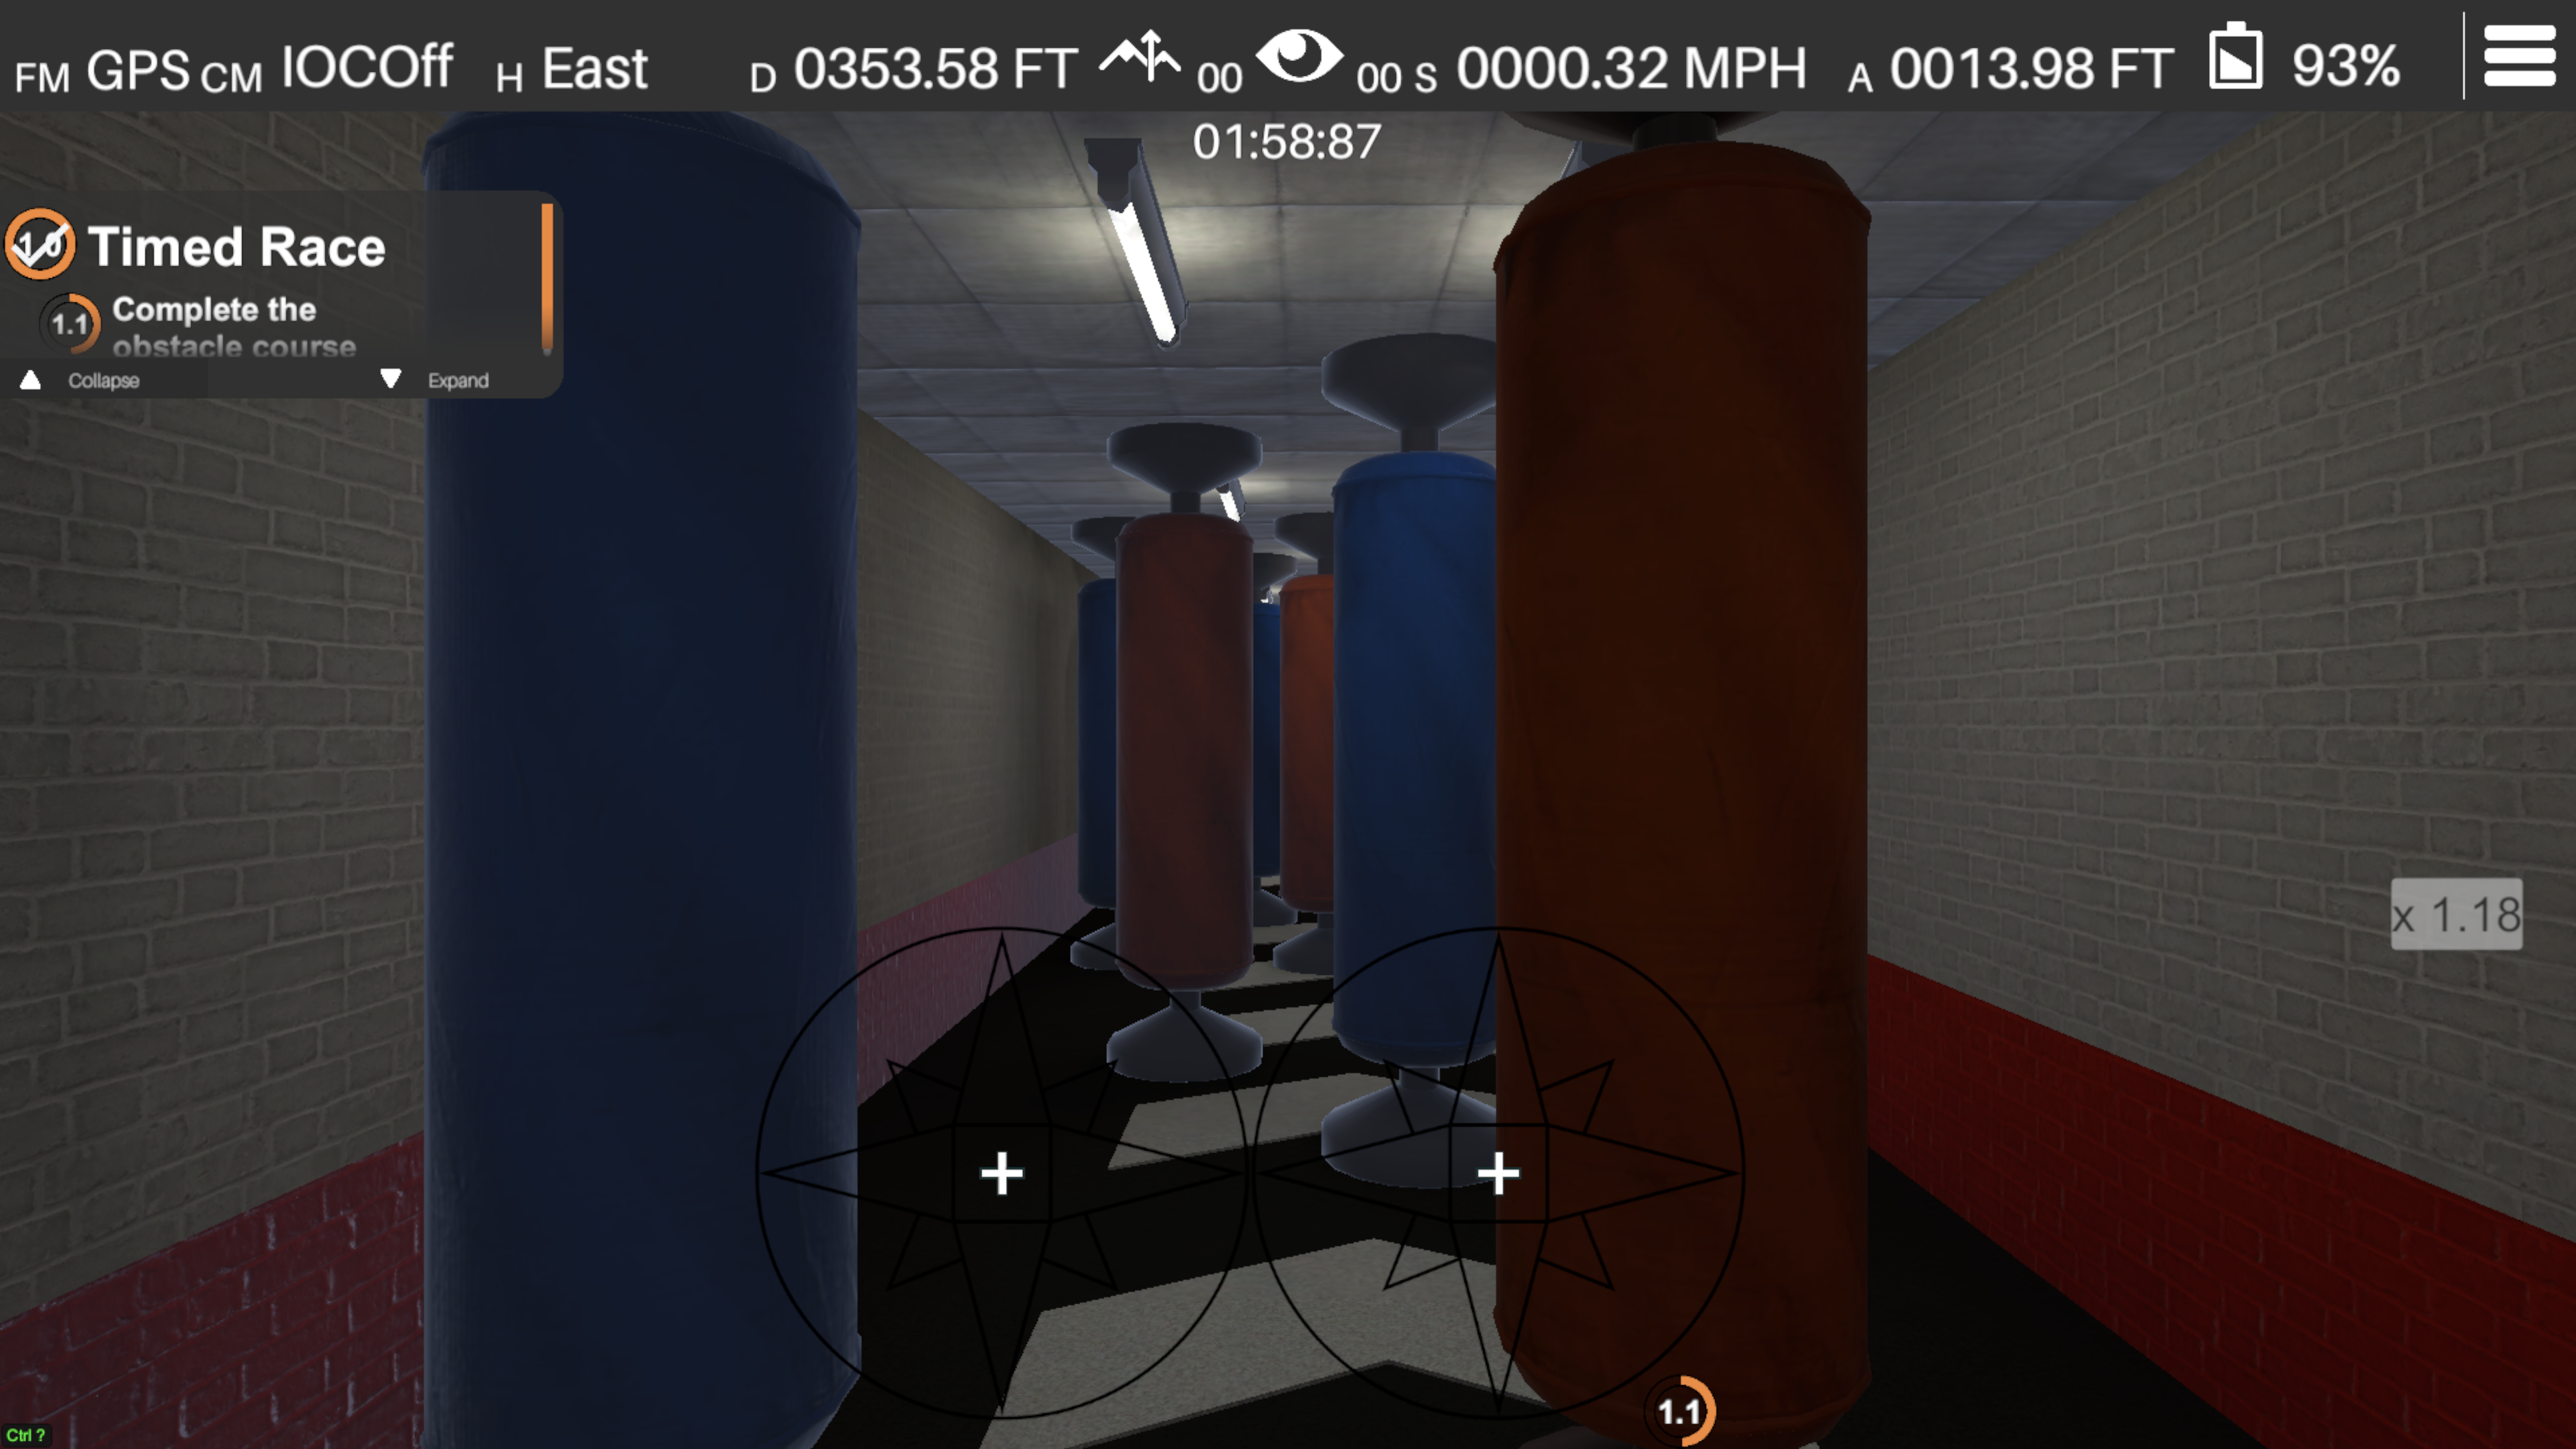
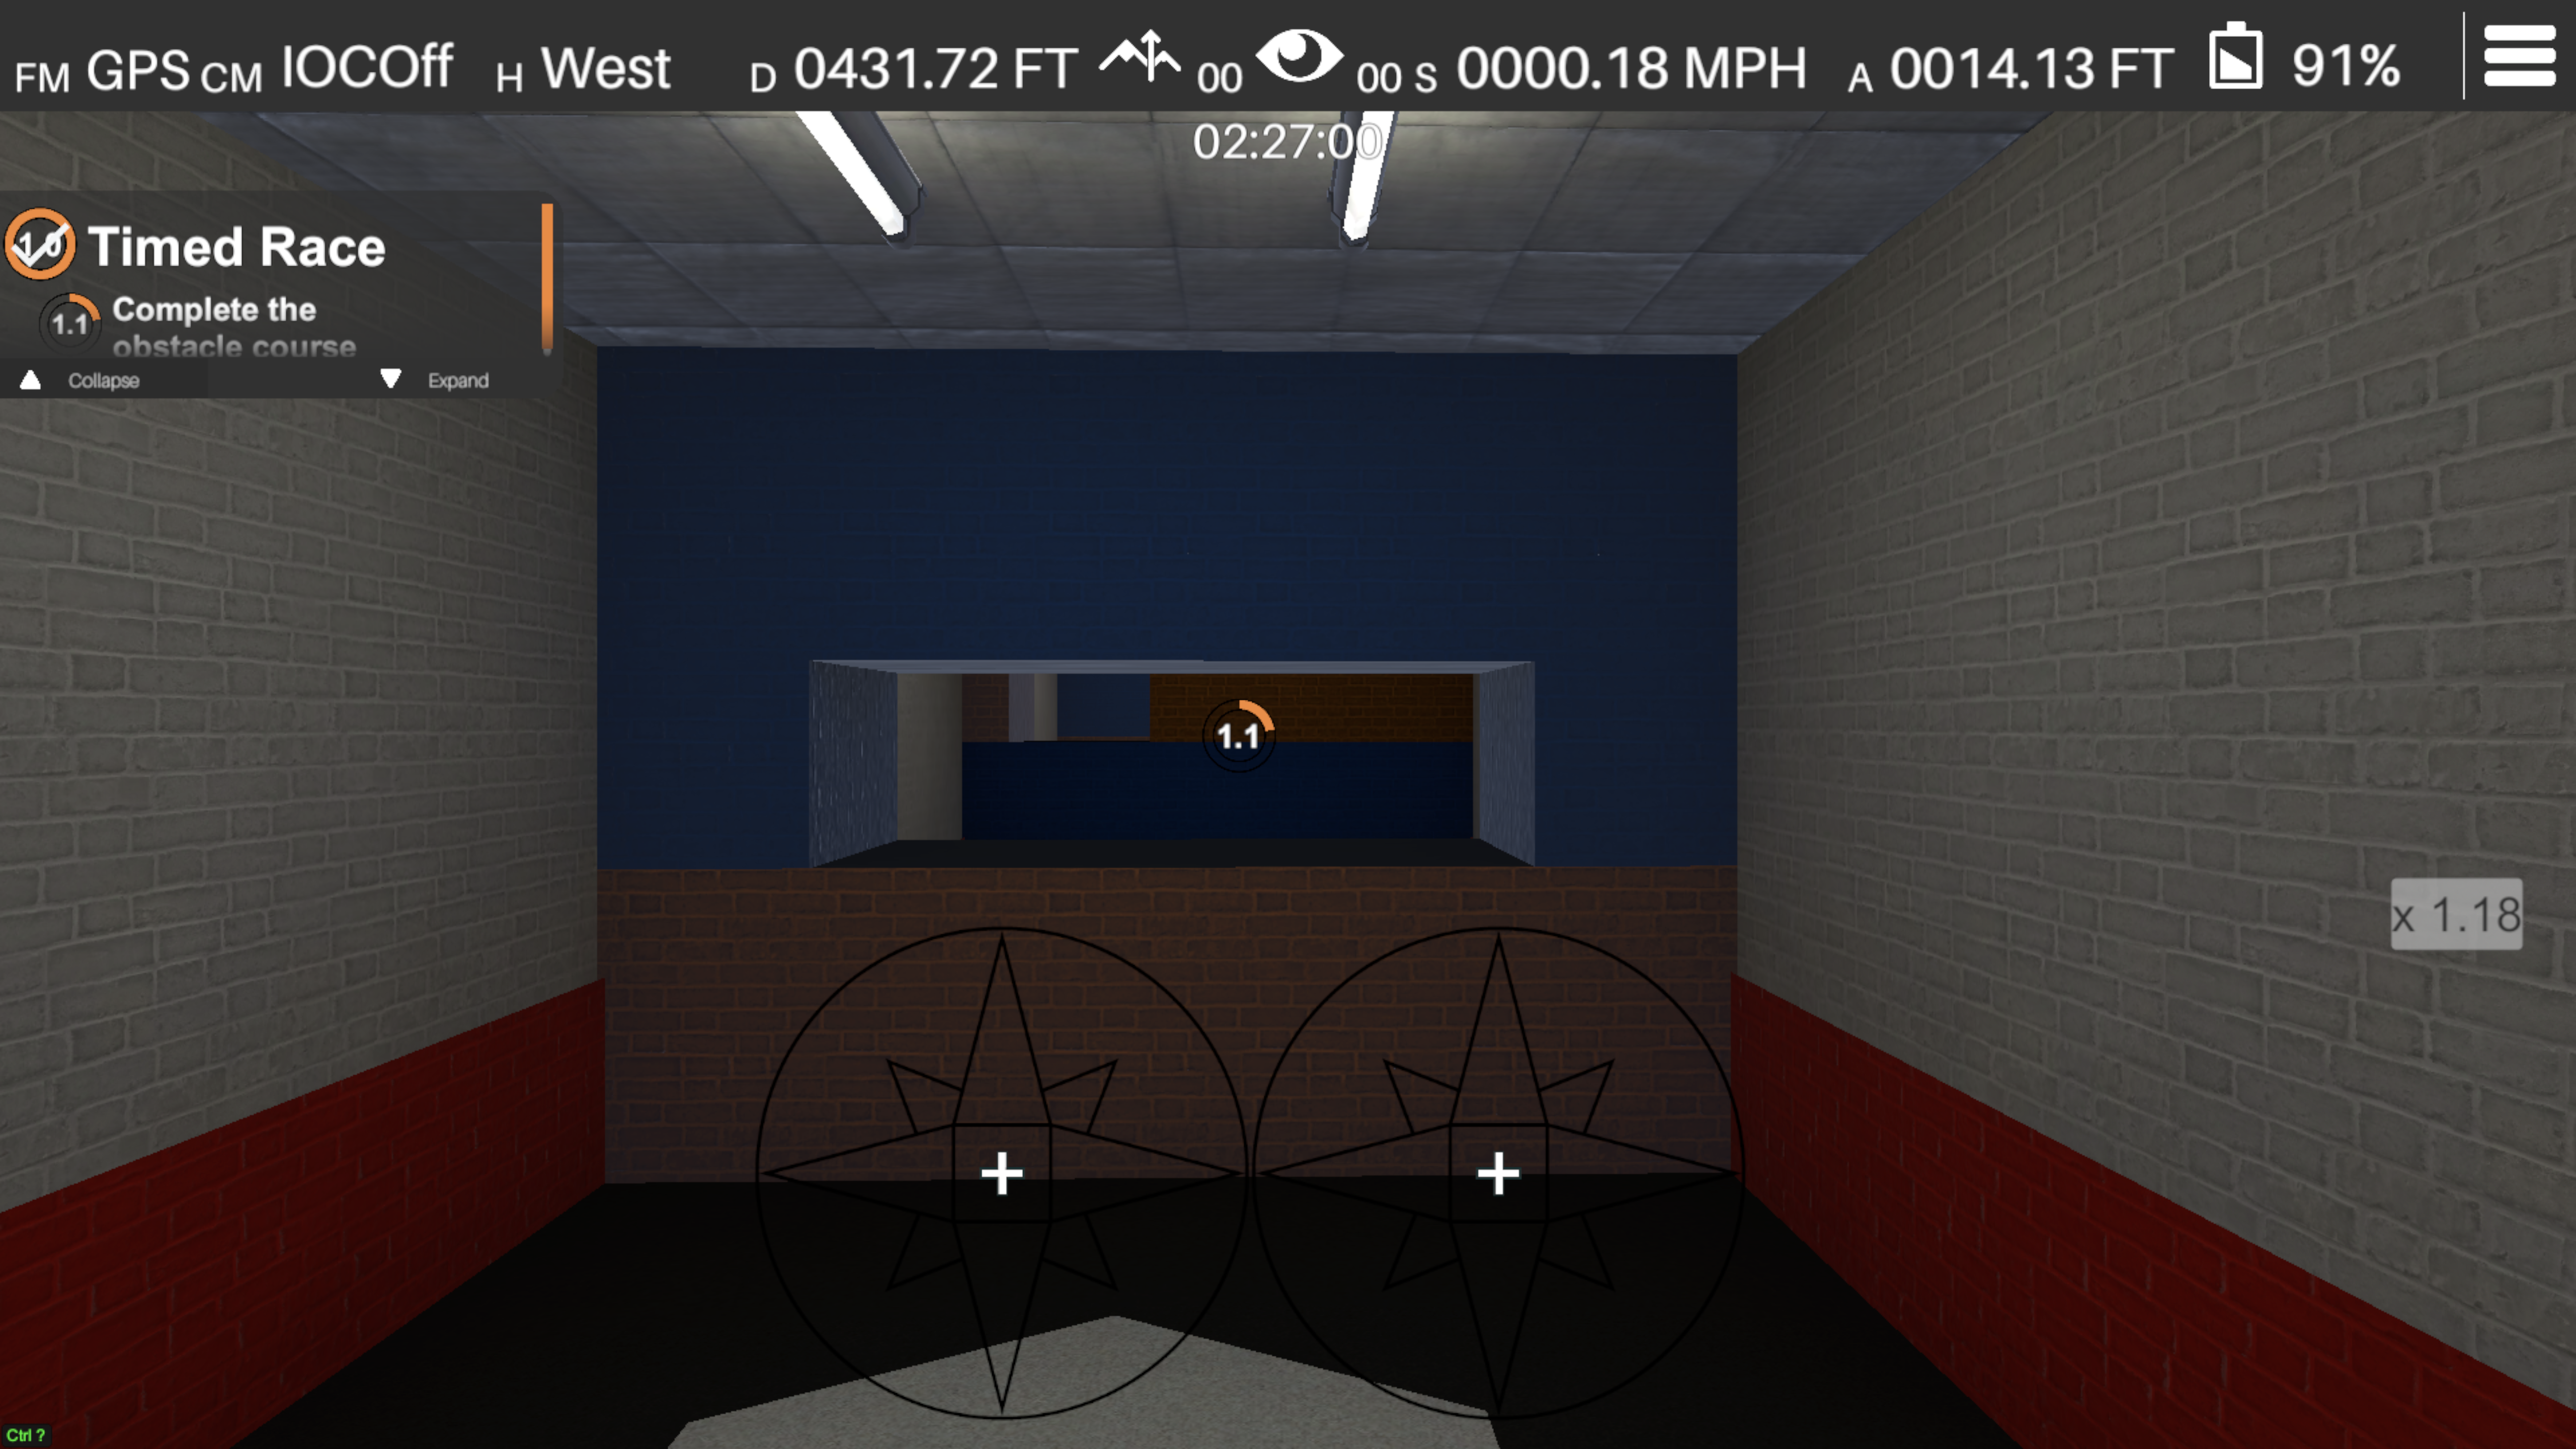
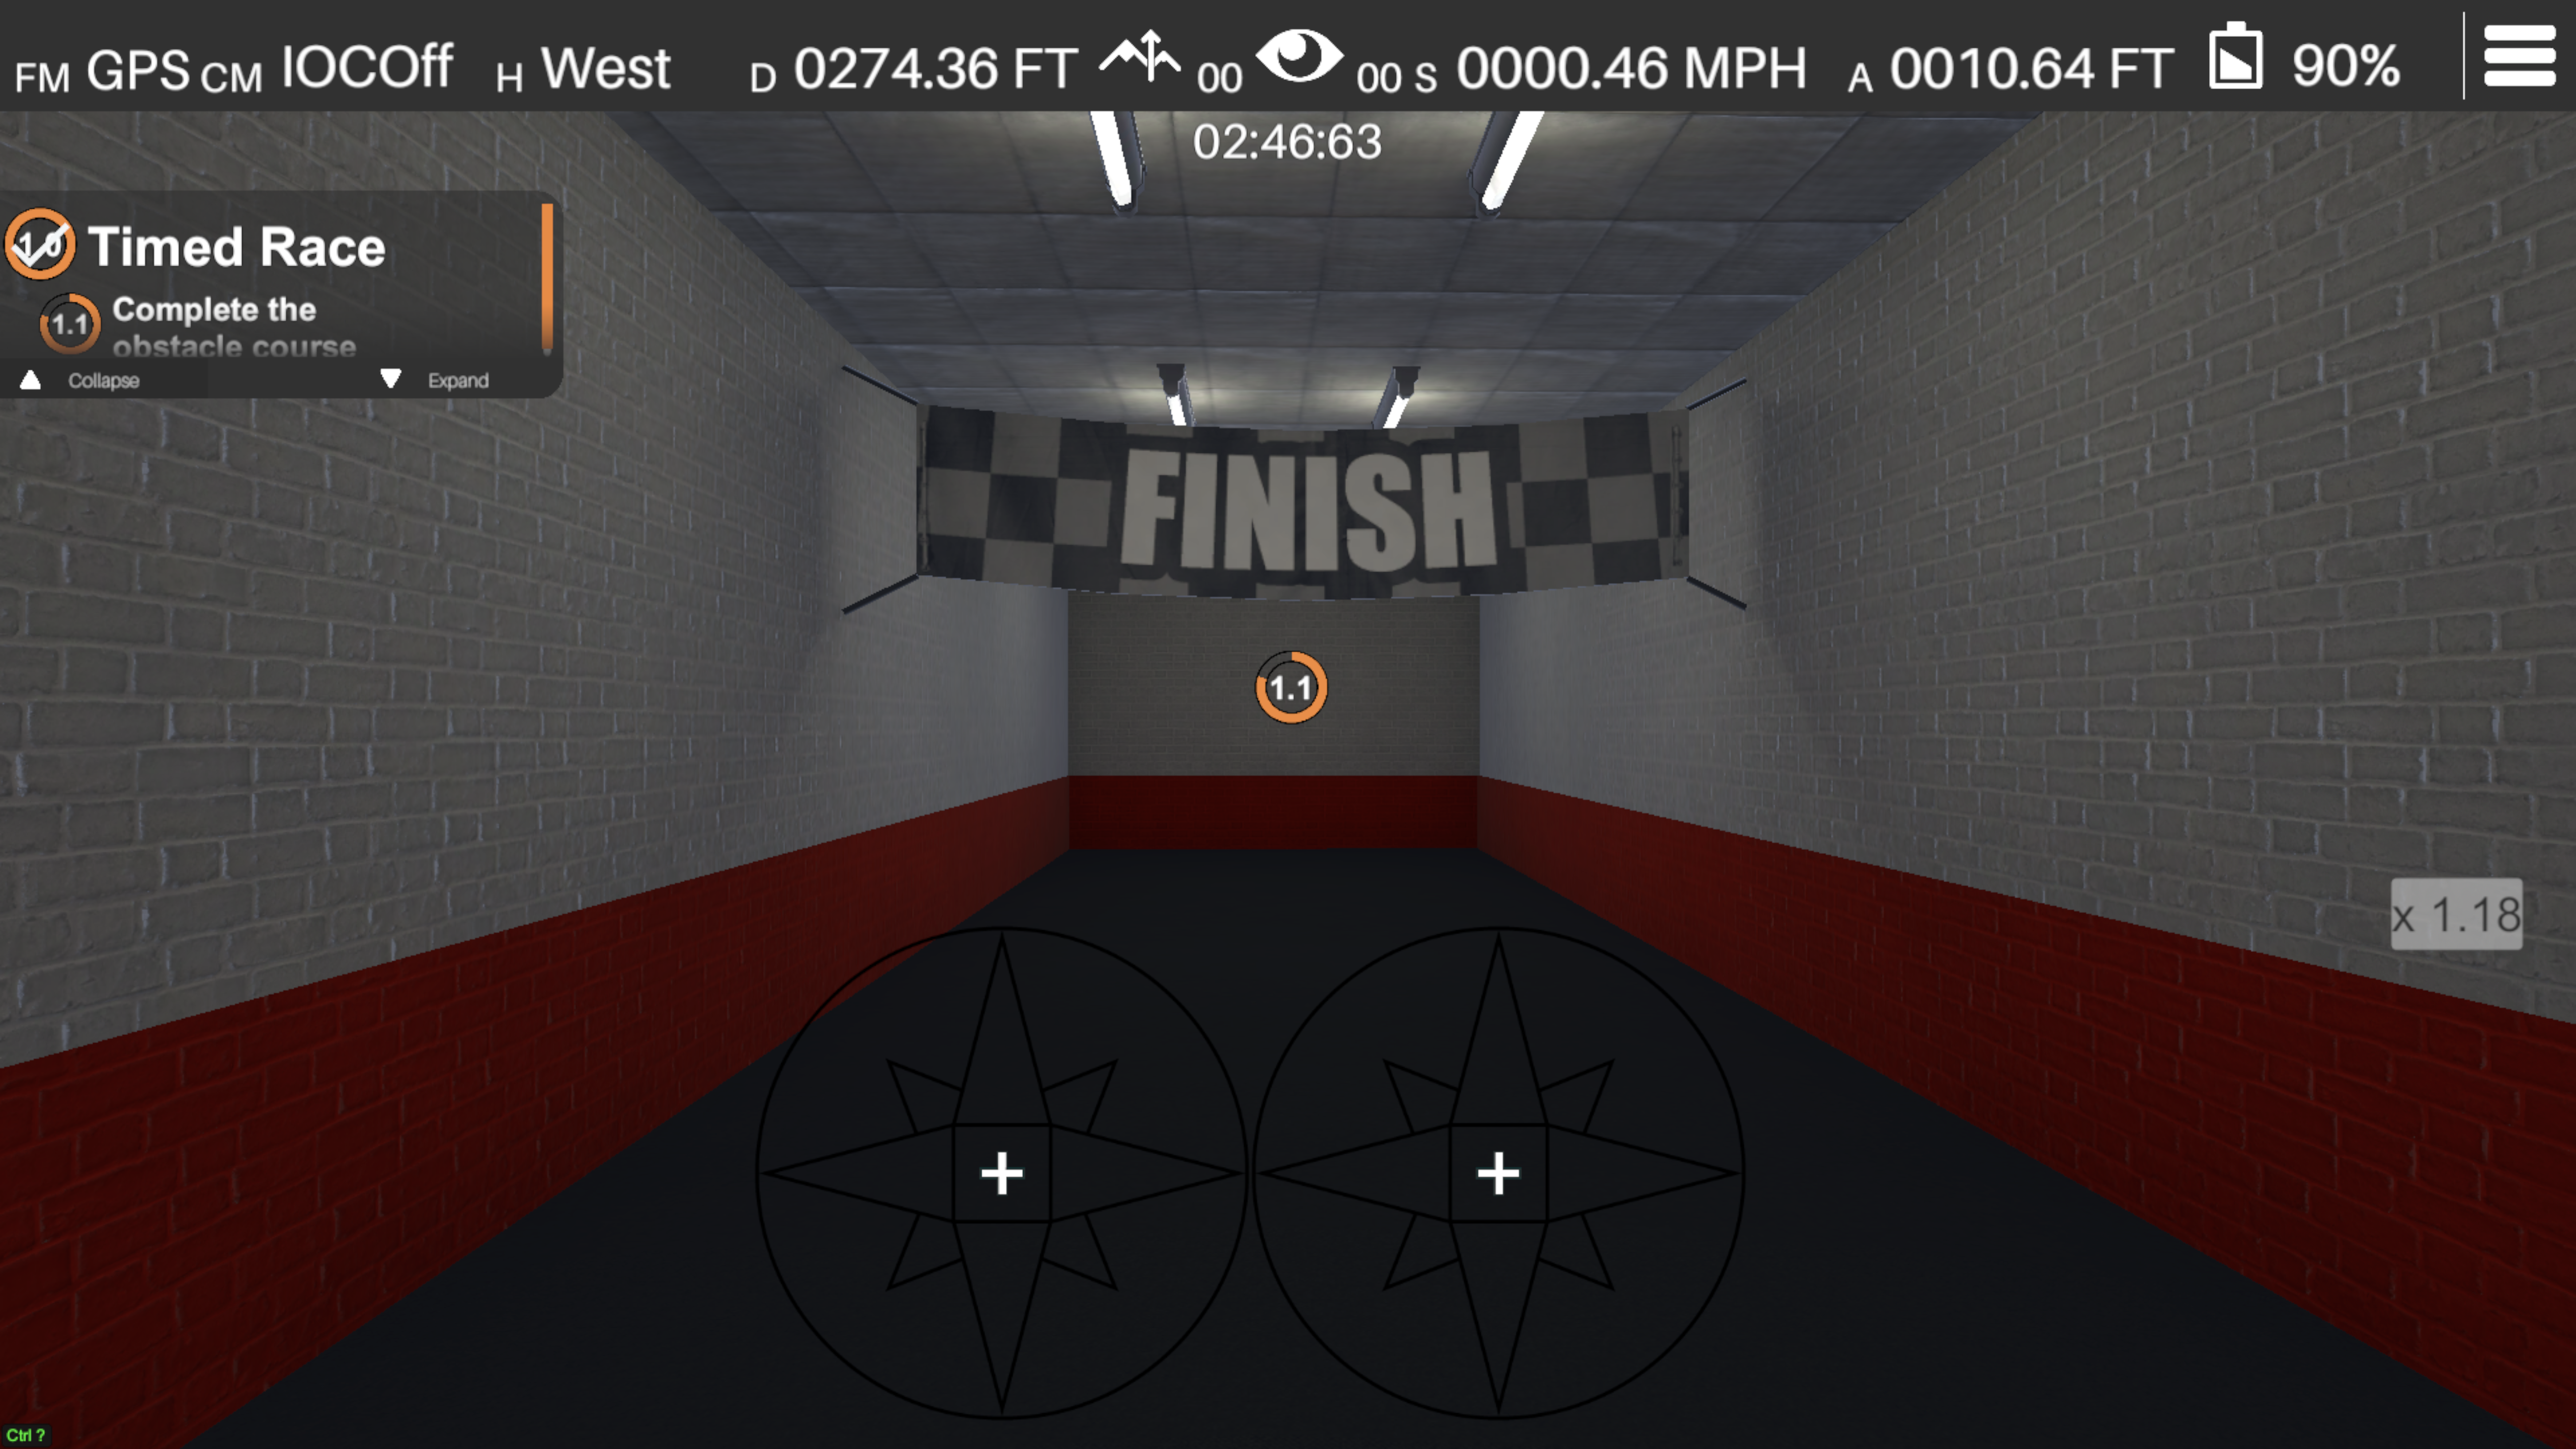
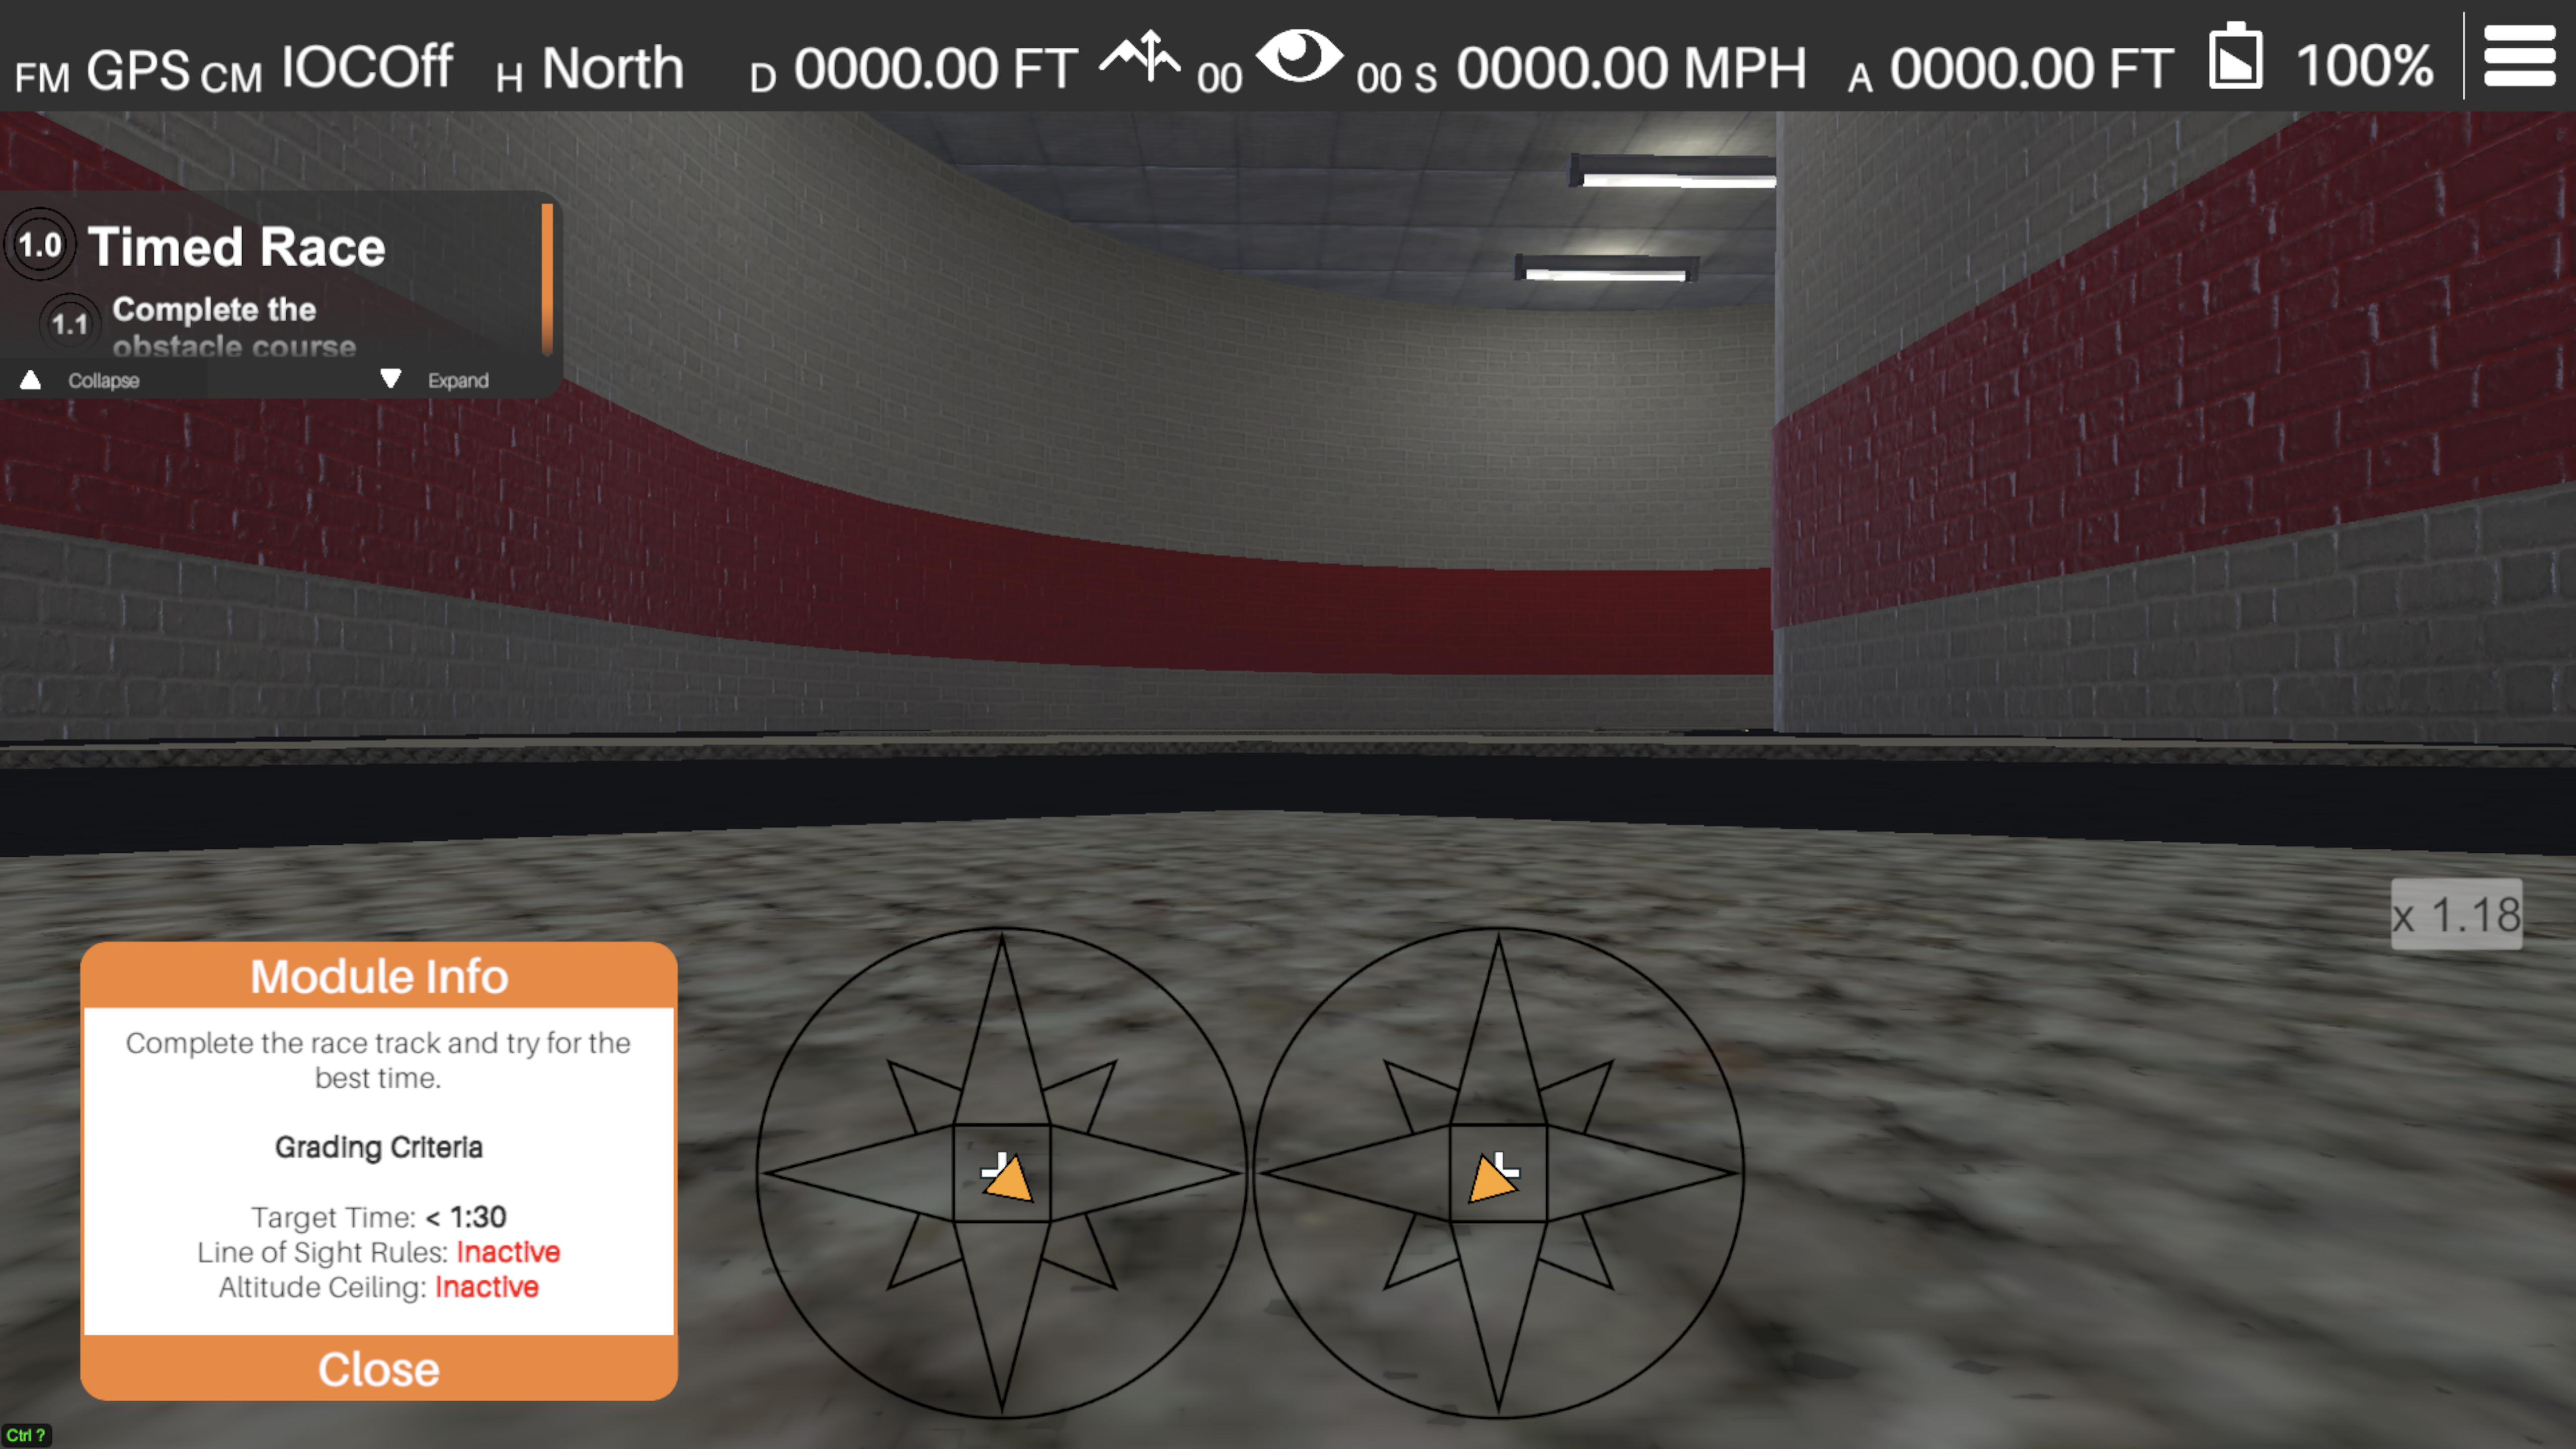
Complete the race track as quickly as possible! The entire module will be flown in first person perspective using the drone's camera.
<figure><img src="https://1836517361-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2Fb4gMJ8PjT5QccaZNi3oB%2Fuploads%2FZM5HXnlXRnqAZgUvQgpn%2Fimage.png?alt=media&amp;token=ca312e72-b77d-4cf4-aa00-913b4c8c5e2e" alt=""><figcaption></figcaption></figure>

<figure><img src="https://1836517361-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2Fb4gMJ8PjT5QccaZNi3oB%2Fuploads%2F2YkgK7rsyvtLtFZFwn6n%2Fimage.png?alt=media&amp;token=4be1e64b-f4f5-492c-9375-deea85cbe4ca" alt=""><figcaption></figcaption></figure>

<figure><img src="https://1836517361-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2Fb4gMJ8PjT5QccaZNi3oB%2Fuploads%2F7Z0cWTToF2Uc2qQgZGzA%2Fimage.png?alt=media&amp;token=84efeb2c-0683-40a4-82b2-1f1b03ff51ad" alt=""><figcaption></figcaption></figure>

<figure><img src="https://1836517361-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2Fb4gMJ8PjT5QccaZNi3oB%2Fuploads%2FFzT1H9f0ByNIZPAq3K6O%2Fimage.png?alt=media&amp;token=a18fe7be-2266-474c-887f-6cc507c63520" alt=""><figcaption></figcaption></figure>

<figure><img src="https://1836517361-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2Fb4gMJ8PjT5QccaZNi3oB%2Fuploads%2FgUYfZDNHw33n6cDBD9y7%2Fimage.png?alt=media&amp;token=1350fcb6-f549-44a5-9d33-7ed1961604b7" alt=""><figcaption></figcaption></figure>

<figure><img src="https://1836517361-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2Fb4gMJ8PjT5QccaZNi3oB%2Fuploads%2F6kVC6oVo2bD7cZ3Aztdp%2Fimage.png?alt=media&amp;token=f314aedd-baa2-4cbd-8f07-c61ced475f0c" alt=""><figcaption></figcaption></figure>